DexGrip-3F 三指自适应夹爪
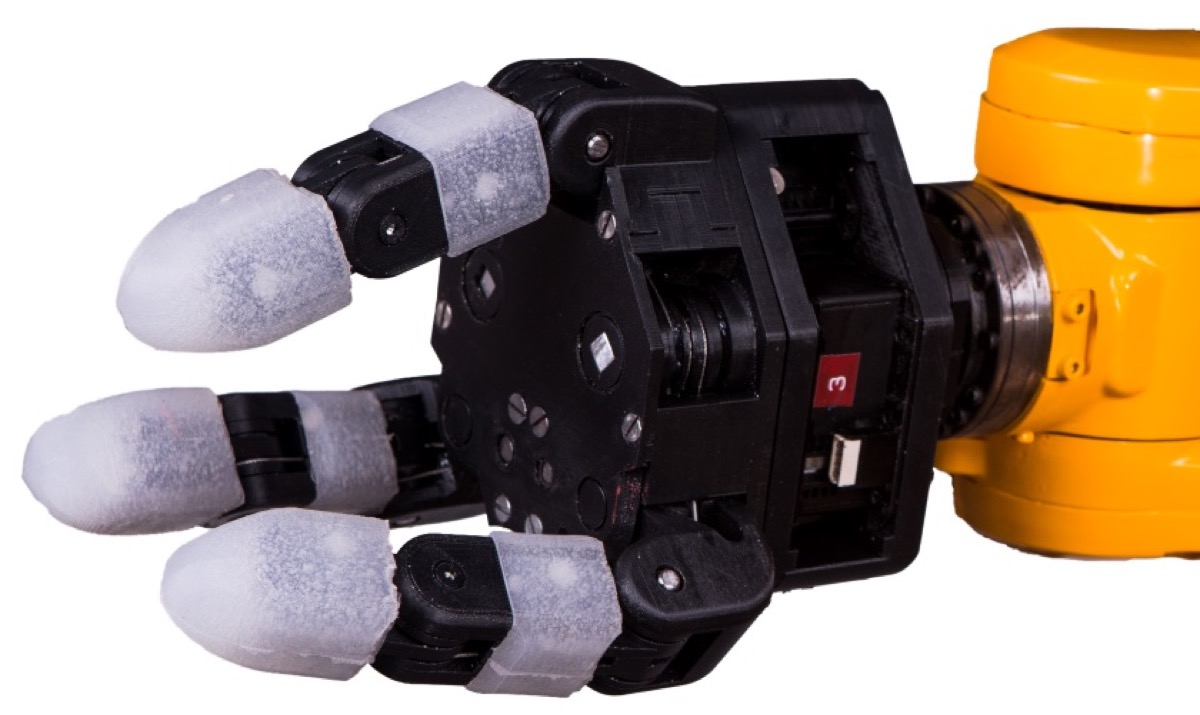
DexGrip-3F 是一款三指自适应通用末端执行器,在“控制简易度”与“抓取稳定性”之间取得平衡:三根手指呈 120° 对称分布,多关节联动,接触物体后自动顺应轮廓收紧,不挑物体形状。
三种抓取模式
| 模式 | 动作 | 适合对象 |
|---|---|---|
| 包夹 Enveloping | 三指像手掌一样将物体整体包裹在手心,力夹角 120° 对称分布,包住后极难滑脱 | 球体、柱体、沙包等无固定形状 / 易变形的软质物体 |
| 捏夹 Pinch | 仅用三指指尖精准对位捏取 | 细小零件、轻薄物体、微调作业 |
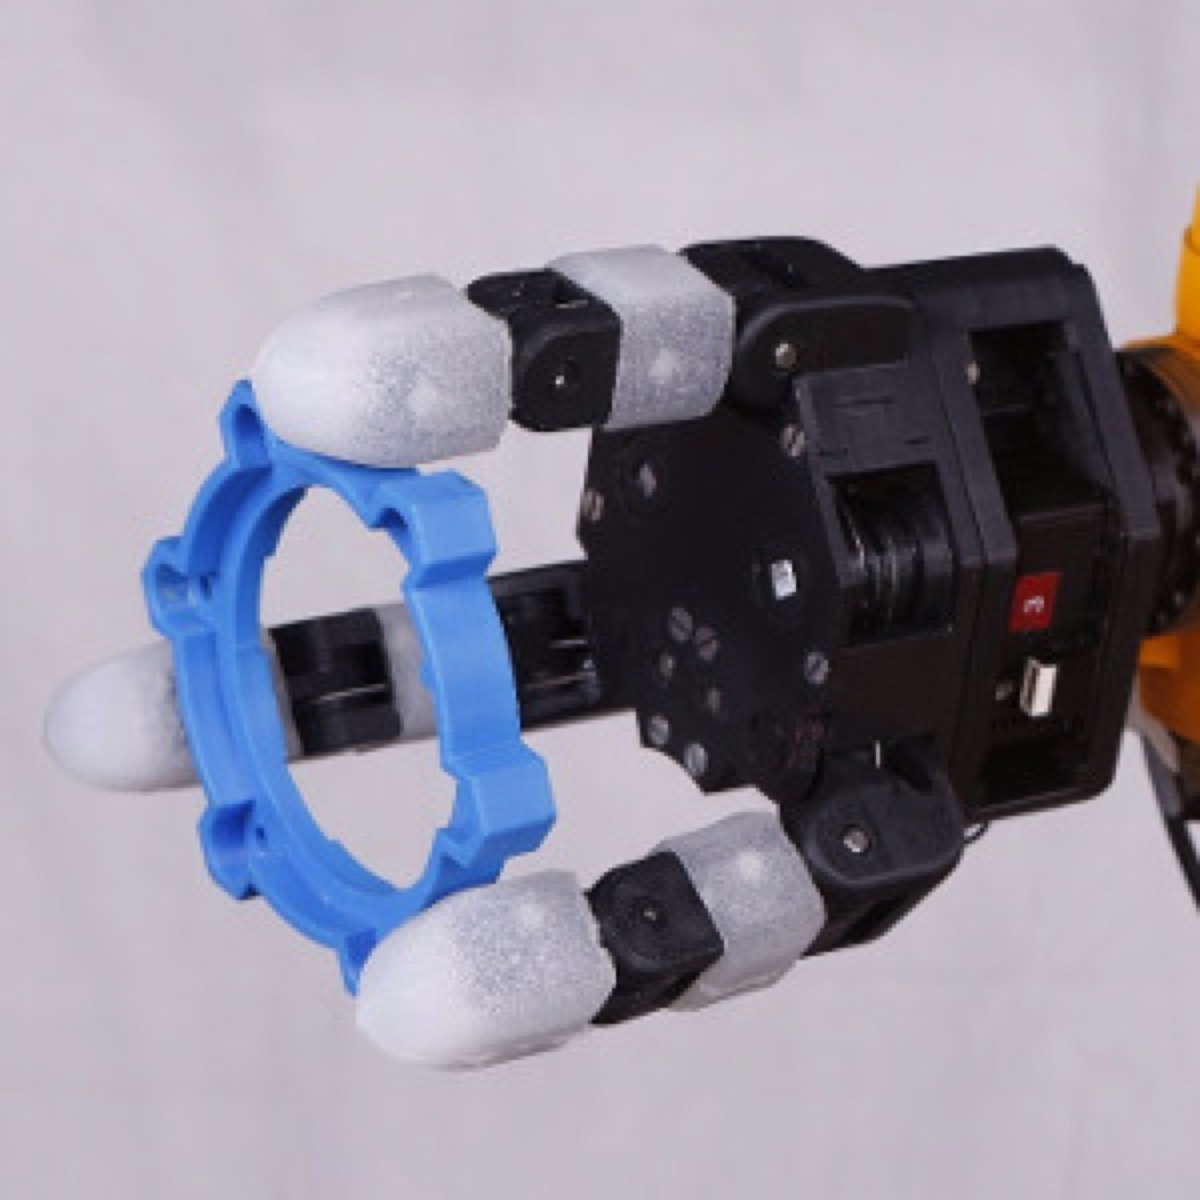
| 内撑 Internal | 手指反向发力,从空心物体内壁向外撑开固定 | 管件、环状物 |
技术优势
- 自适应抓取:手指多关节联动,接触物体时随表面轮廓形变直到贴合,对位误差容忍度高
- 三点对称锁死:120° 等距结构提供向心会聚的抓取力,克服两指夹爪受力不均导致的侧滑
- 高负载自重比:自重轻、抓取力大,适合无人机背负与机械臂末端
- 力控反馈:可调抓取力,既能抓紧重物,也能不捏碎易碎件
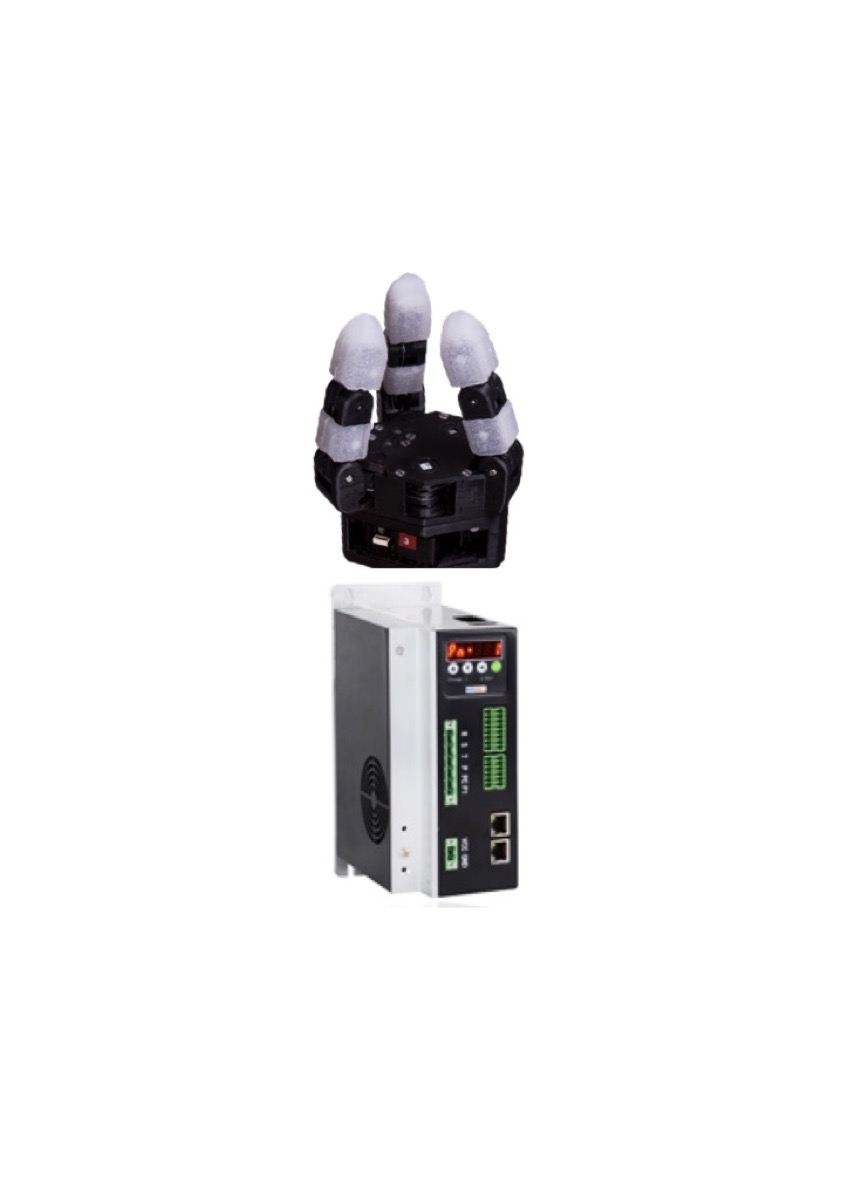
- 配套伺服驱动器与上位机,可与 DexHand-5F 共用控制平台
典型应用
- 无人机抓取与投放(如沙包、包裹):夹爪罩住目标后自动收紧,用机械自适应弥补悬停对位误差,实现可靠“盲操抓取”
- 机械臂拾取不规则物体、软包与球体
- 实验室 / 教学:与灵巧手同一控制器,便于对比研究
购买
通过询盘获取匹配规格的 PDF 报价;远程实机测试体验包 ¥199–499,订购时全额抵扣。
实拍视频
English summary — DexGrip-3F three-finger adaptive gripper
DexGrip-3F by Wuhan Jingling Qiaoshou Robotics Co., Ltd. is a three-finger adaptive end effector with three grasp modes: enveloping (spheres, cylinders, soft bags), pinch (small parts) and internal (pipes, rings). Fingers sit at 120° with linked joints that conform to the object, giving high tolerance to misalignment — well suited to drone-mounted grasping and robot-arm pick-and-place.
- High payload-to-weight ratio; adjustable grip force with force feedback
- Ships with a servo drive and GUI; shares the control platform with DexHand-5F
- Quotes on request; Remote Test Drive ¥199–499 credited against purchase
Contact: 13707145255@139.com · Tel/WeChat +86-137-0714-5255.