Launch offer Simulation Kit 20% off the first year (¥1,599) + dataset sample pack · ends 2026-12-31 Subscribe →|Labs: loaner program →
Dexterous manipulation platform

Dexterous manipulation infrastructure for embodied AI.

Our own five-finger dexterous hand and three-finger adaptive gripper, with SDKs, simulation, datasets and benchmarks — take a policy from simulation to a real gripper.

从仿真到实机的灵巧操作技术平台 · 手 / SDK / 数据集 / 评测

DOF17 · 22 joints
LATENCY8 ms
GRIP FORCE4.2 N
REPEATABILITY±0.02 mm
Demo reel loading…
Runs in your stack ROS 2NVIDIA Isaac SimMuJoCoGazebo
17degrees of freedom
±0.02mmrepeatability
8mscontrol latency
HDF5·RLDSdataset formats
Build · Simulate · Control · Deploy

One stack from a natural task to a real gripper.

Start in simulation with our URDF and datasets, train a grasping policy, validate it in a digital twin, then run the same policy on real hardware over ROS 2 — the control and safety layer stays the same the whole way.

Hardware · Built in-house

A five-finger dexterous hand, a three-finger adaptive gripper, and the servo drives behind them.

Everything below is designed and built by us and runs in our lab and at customer sites. Photos and videos are real footage.
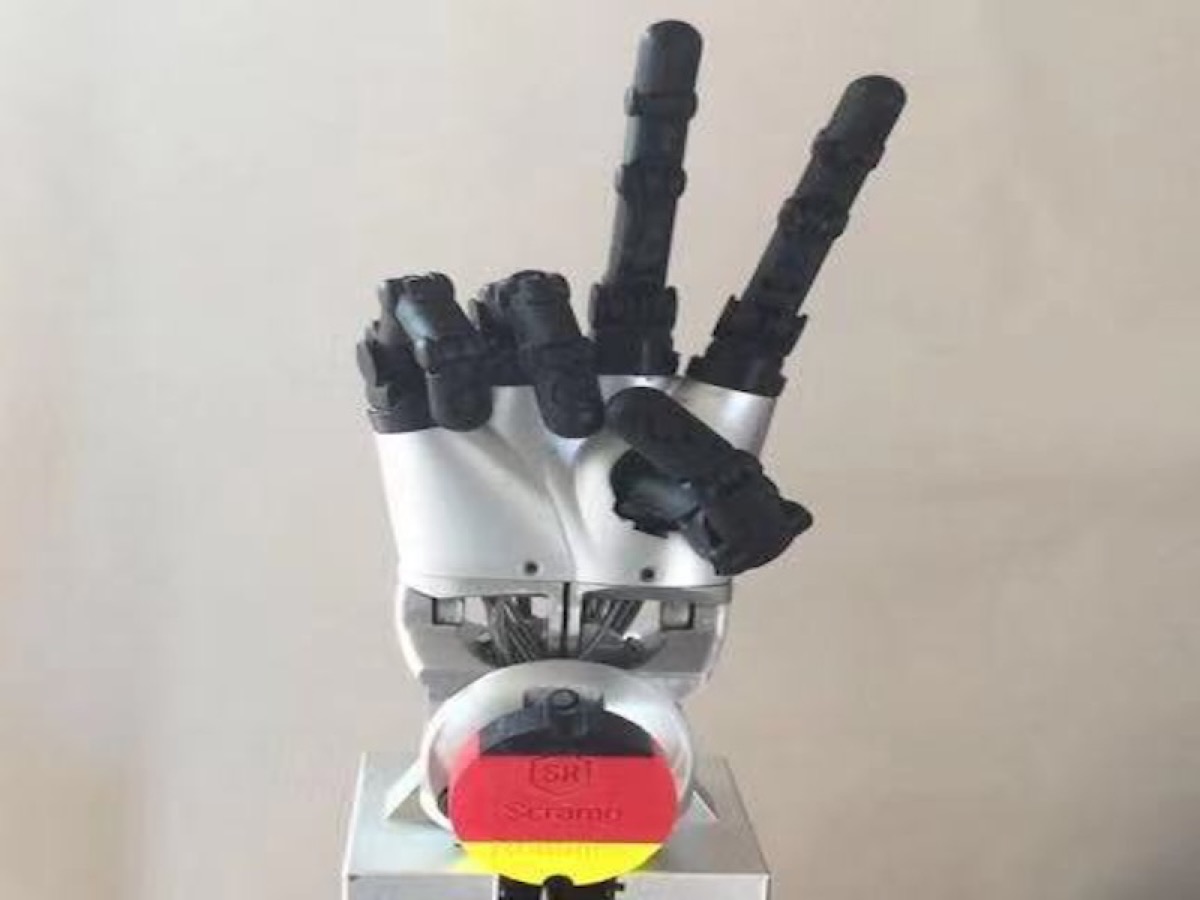
Five-finger dexterous hand
DexHand-5F · Gen 1 (shipping)

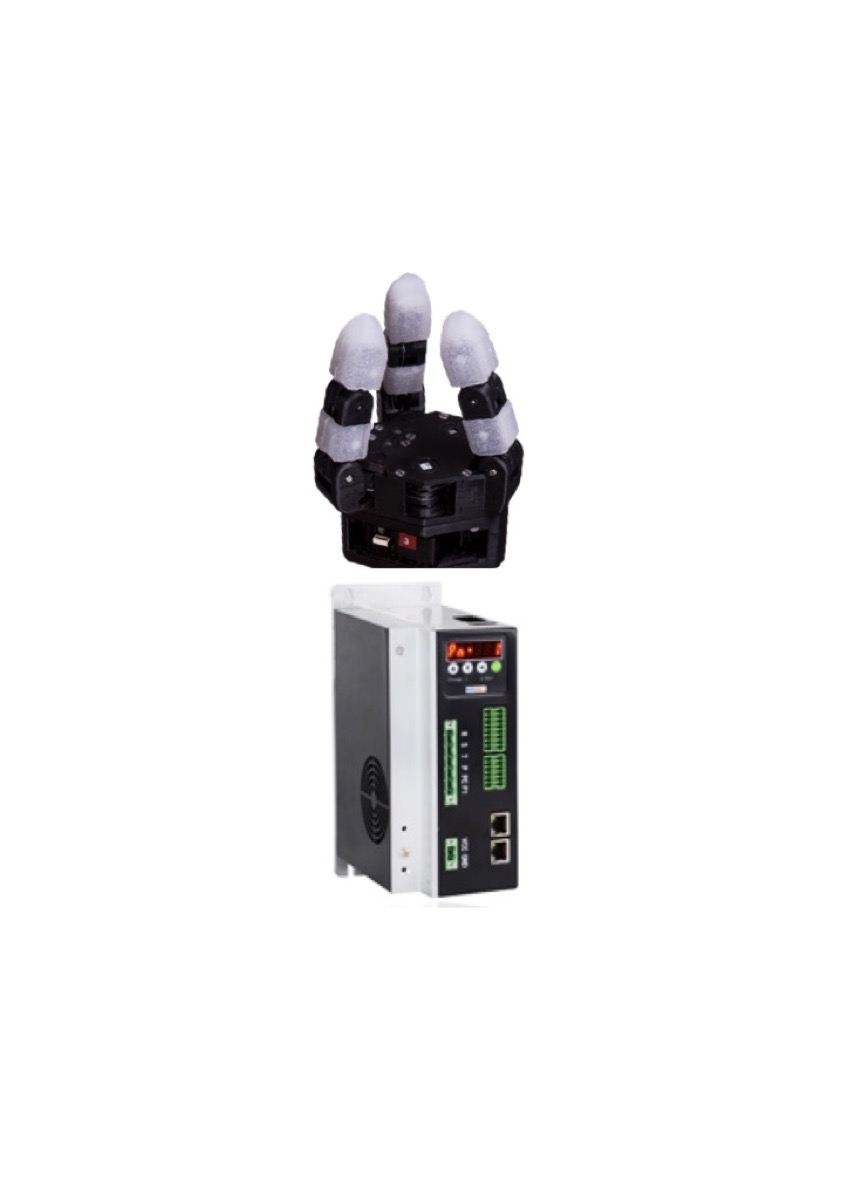
Five-finger bionic dexterous hand

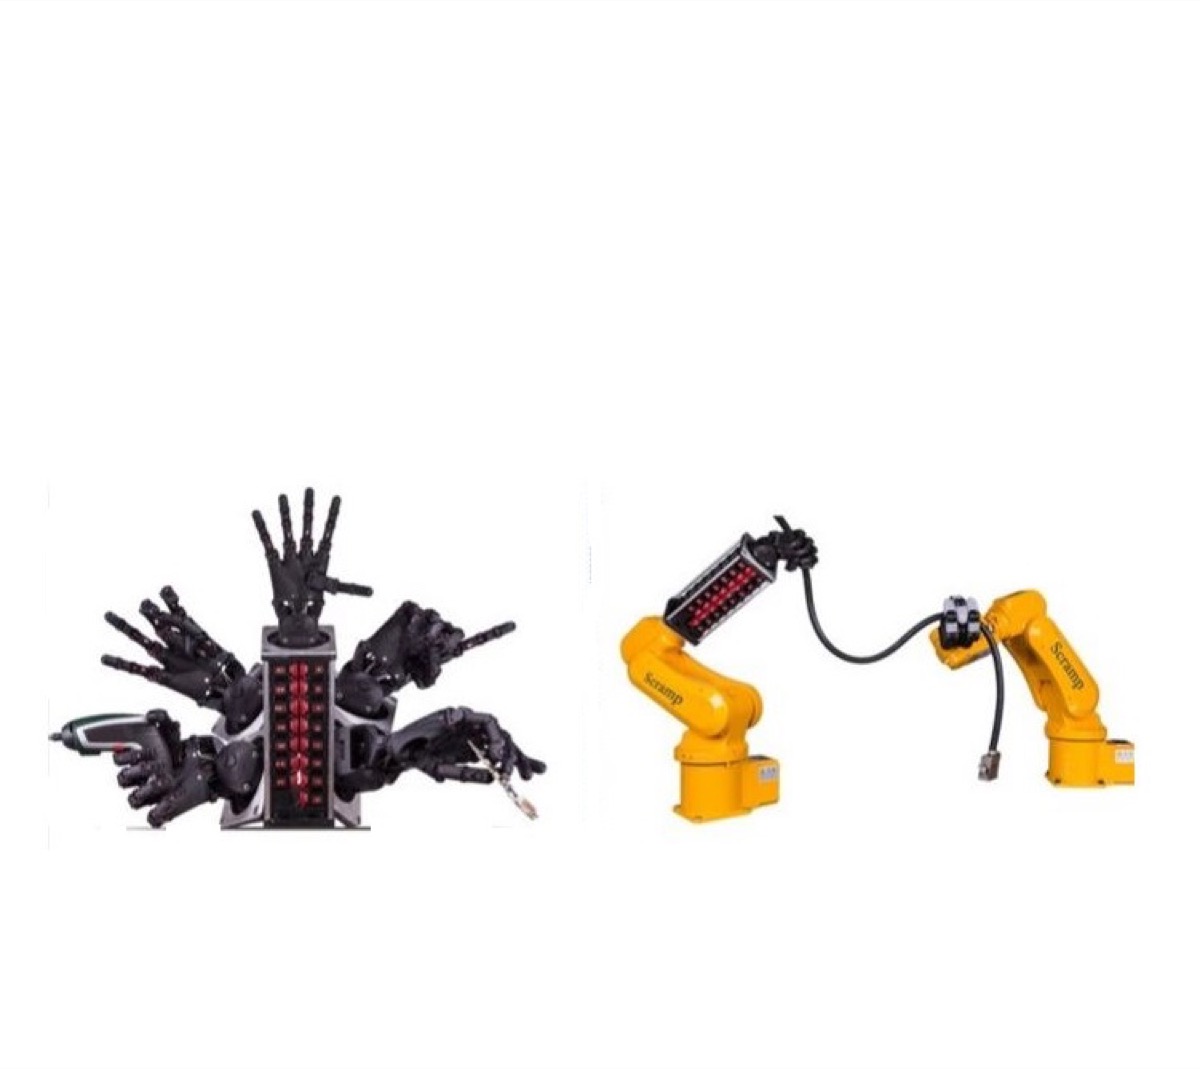
  • 17 servo motors, 17 active DoF, independent finger flexion and thumb opposition
  • Left and right hands as a pair; mounts on 6-axis arms, parallel robots or humanoid bodies
  • Comes with a multi-axis servo drive tower, EtherCAT bus, CODESYS / in-house GUI programming
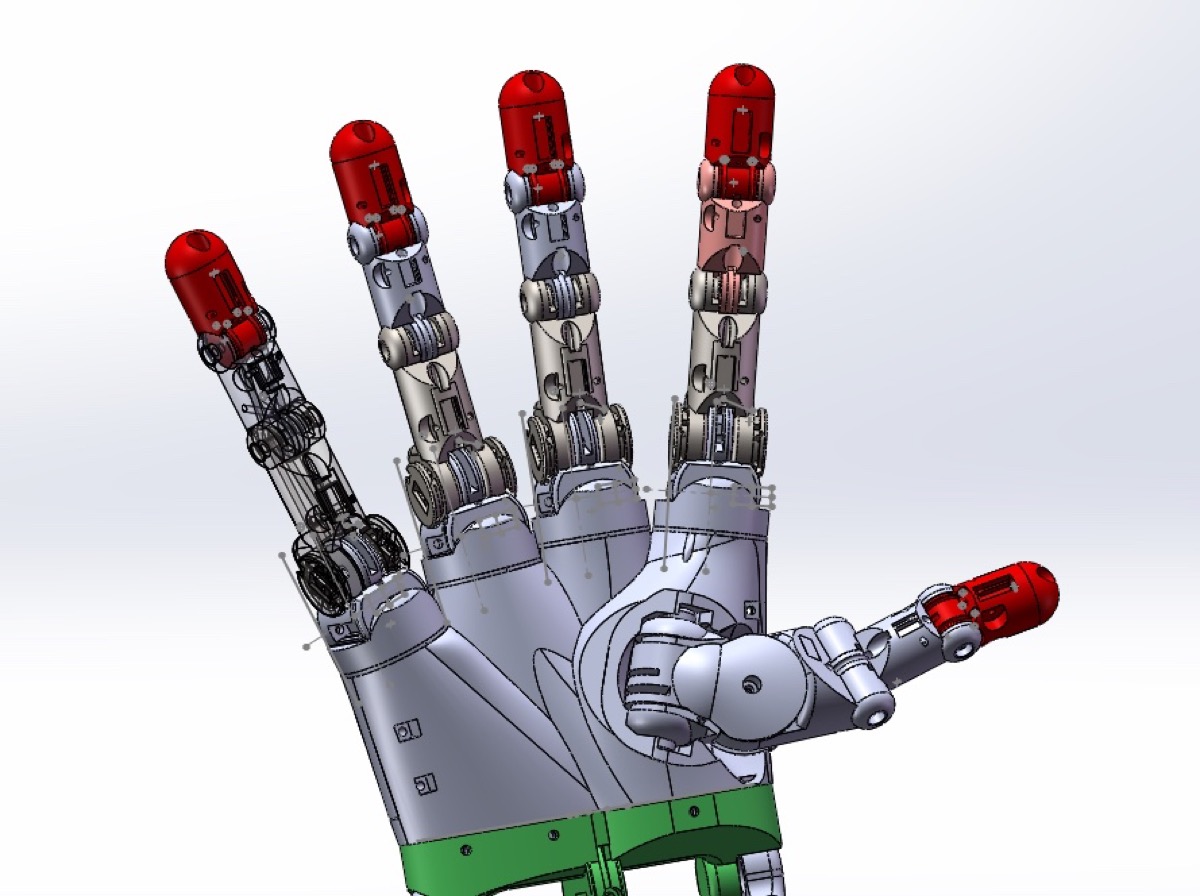
  • A virtual hand identical to the real one for offline programming and live co-simulation on the same controller
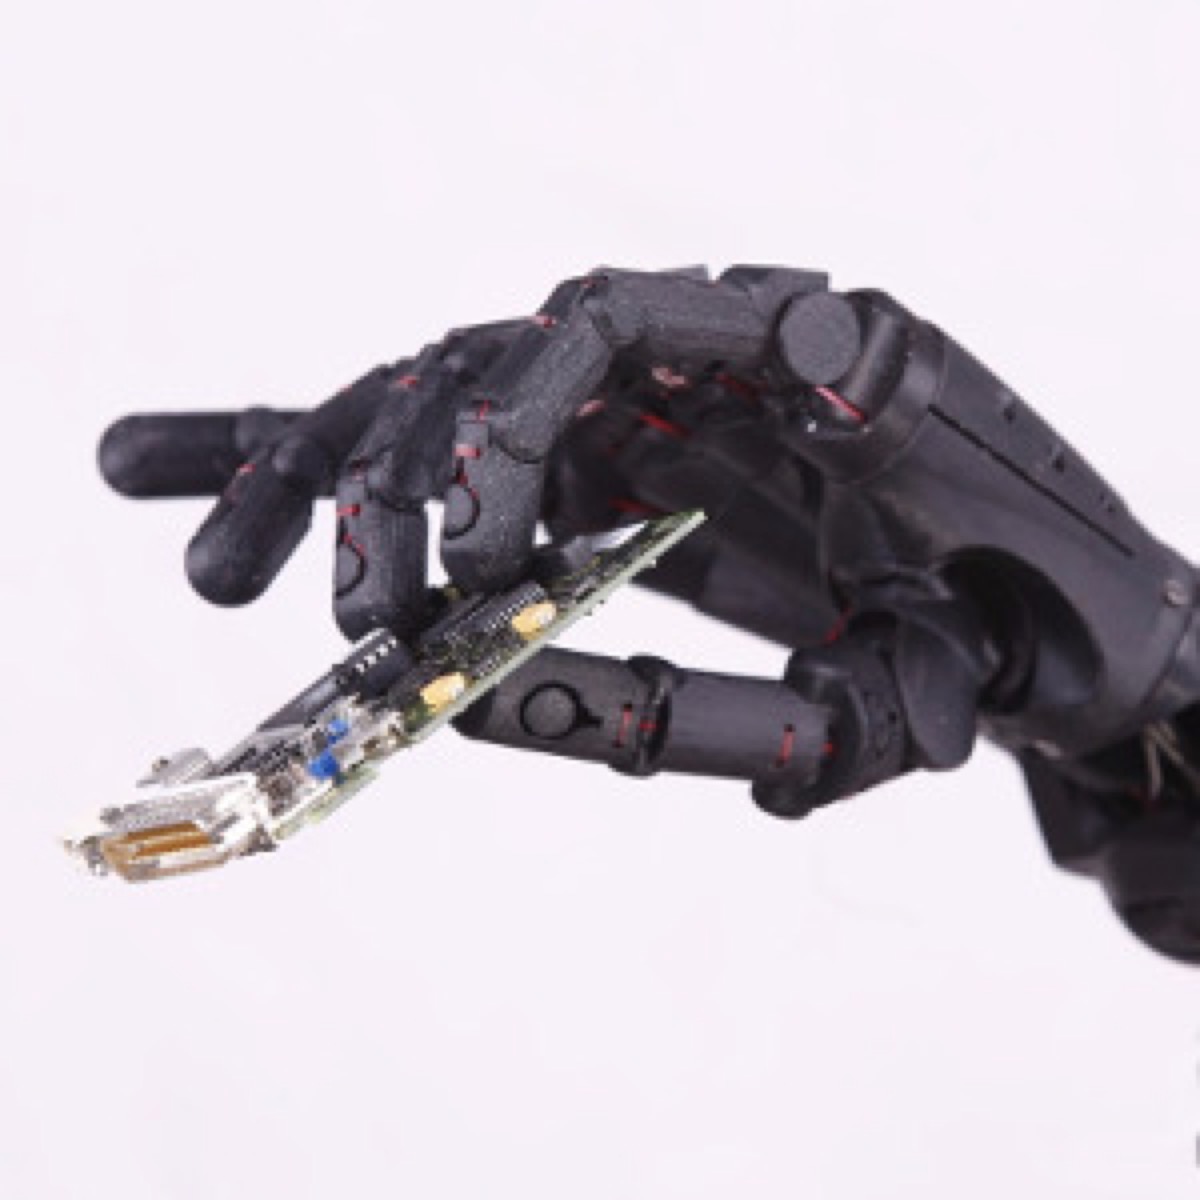
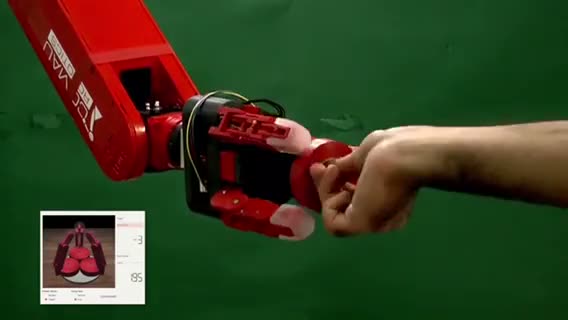
  • Demonstrated: grasping PCBs, tools and everyday objects; EMG (muscle sensor) driven control
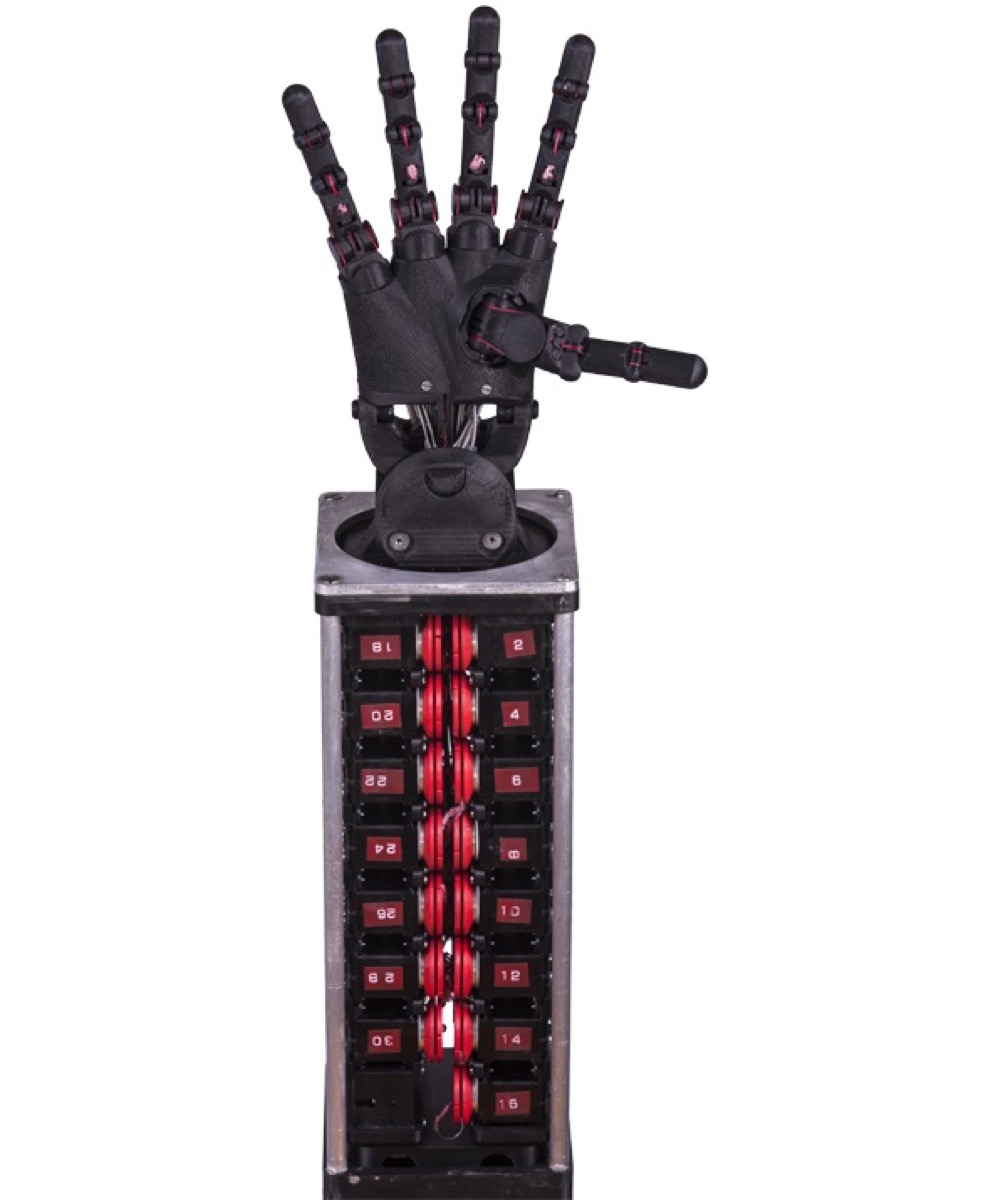
Hand with drive tower Hand grasping a PCB Hand product family Hand CAD model
Three-finger adaptive gripper
DexGrip-3F

Three-finger adaptive gripper

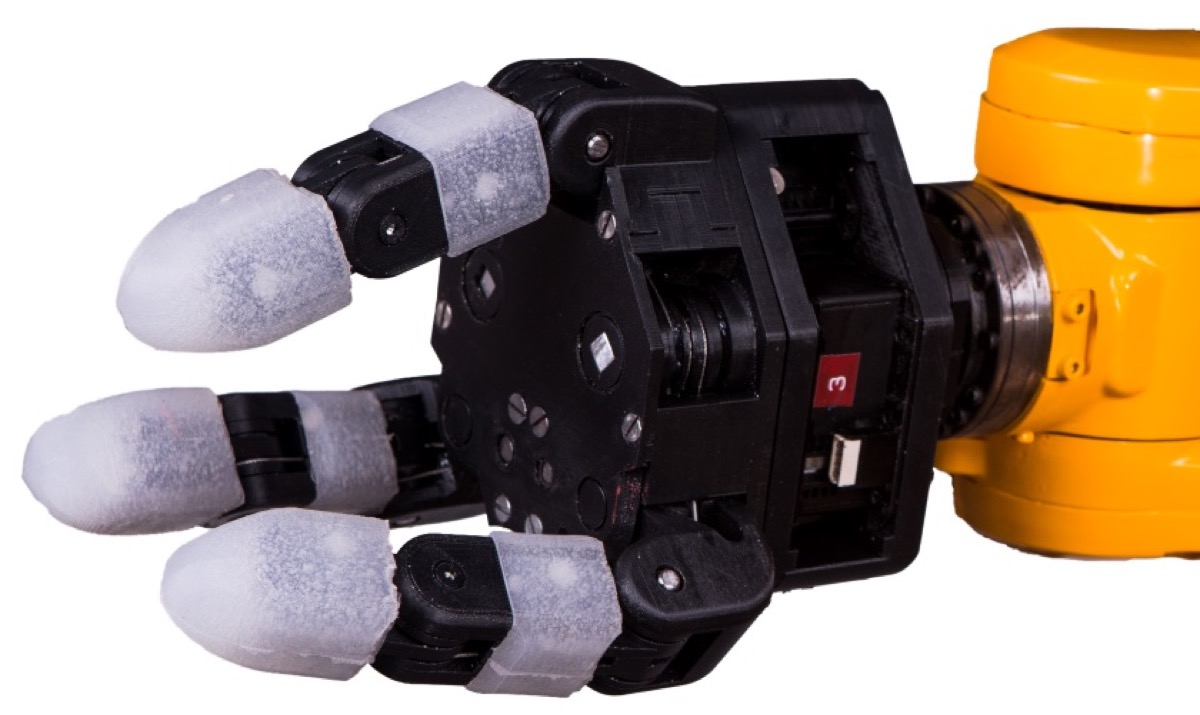
  • Three grasp modes: enveloping (spheres, cylinders, soft bags), pinch (small parts), internal (pipes, rings)
  • Fingers at 120° with linked joints that conform to the object — high tolerance to misalignment
  • High payload-to-weight ratio for arm end-effectors and drone-mounted grasping
  • Force feedback: adjustable grip force for heavy and fragile parts alike
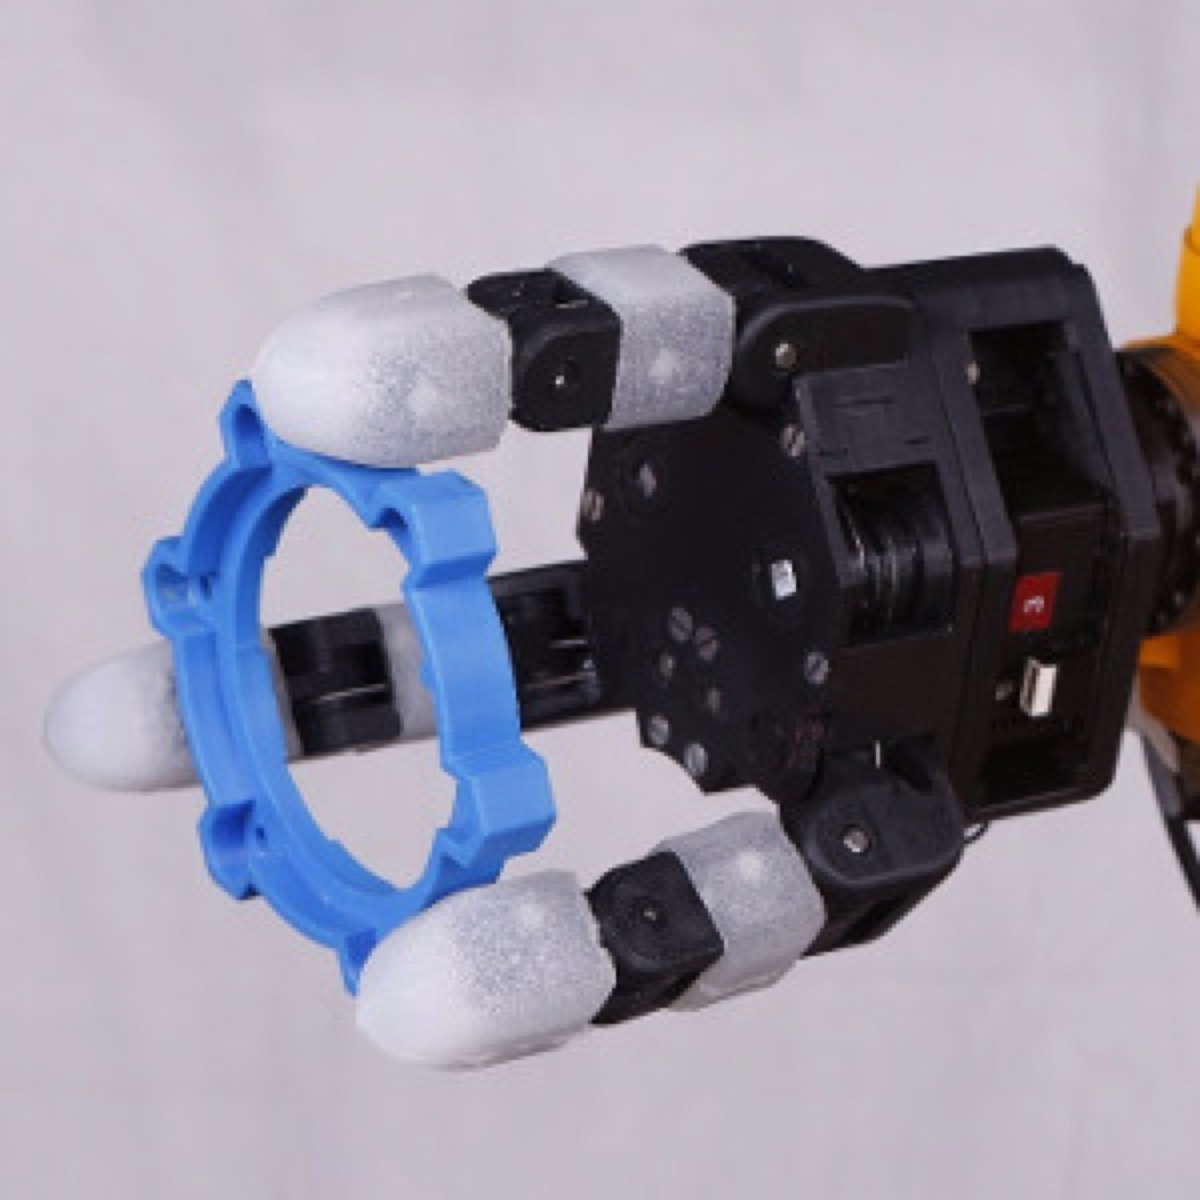
Gripper holding a ring Gripper and servo drive Gripper video
Watch footage
Roadmap

From external motors in Gen 1 to a forearm-integrated, tendon-driven Gen 2.

Gen 1 proved high-DoF control on real hardware and in simulation. Gen 2 moves every actuator into the forearm to meet the protection, stiffness and size demands of humanoid and industrial use.

Gen 1 · shipping

High-DoF bionic hand · external motors

  • 17 servo motors + multi-axis drive tower, mature control chain
  • Virtual hand and real hand on one controller
  • Suited to research, policy validation, teaching and demos
Limits: hand volume and stiffness, exposed cabling, no IP rating
Videos · 实拍与仿真

See the hand work — on the bench, in simulation, at the fair.

Unedited footage: dexterous-hand control, EMG-driven grasping, controller tutorials and industrial application cases. All videos are served from this site, so they play anywhere — including mainland China.

Featured · Hannover Messe 2016

Live at Hannover Messe

Our team's robot and hand technology demonstrated on the floor at Hannover Messe 2016 — 2 min 46 s, unedited.

汉诺威工业博览会现场演示 · 无剪辑实拍

YouTube channel ↗

Product footage DexHand-5F / DexGrip-3F

Left + right hand pairDexHand-5F · gestures and single-finger motion
Real hand and virtual hand in syncPhysical motion mirrored in simulation
Three-finger gripper demoEnveloping / pinch · grip force overlay

Dexterous hand 灵巧手 · 控制 / 仿真 / 肌电

4:32Dexterous hand programming & CODESYS control with simulation灵巧手编程 · CODESYS 控制与仿真联调
0:21Dexterous hand driven by a muscle (EMG) sensor肌电传感器驱动灵巧手 · 真人测试
0:10Dexterous hand bench test (2018-03)灵巧手台架测试

Controller & simulation tutorials 控制器与仿真教程

CODESYS + GUI · Lesson 4控制器编程课程 4
GUI jog & simulation of the robot controller控制器手动/仿真
GUI robot controller · Lesson 1控制器课程 1
GUI CNC teach-in programming (intermediate)CNC 示教编程 · 中级
BSI servo software basicsBSI 伺服软件基础
BSI new motor adaptation (intermediate)BSI 新电机适配 · 中级

Application cases 应用案例(Delta / SCARA / 打磨)

Robot polishing work station机器人打磨工作站
Delta pick-and-place with visionDelta 视觉拾取
Real machines running at customers客户现场运行
SCARA on flexible PCB软板 PCB 作业
Delta dispensingDelta 点胶
Robot teleoperated from a phone手机遥控机器人

All videos are served from this site; no YouTube access required. For higher resolution or original footage, contact us.

DexHand Benchmark 2026

An open reference for dexterous hands.

Simulated and public-data baselines to start. The test protocol is open — vendors are welcome to claim a profile and post verified physical metrics.

Open test protocol
Hand DoF Payload Repeatability Latency Source
DexHand SCP-E5 17 — ±0.02 mm 8 ms Simulated
Shadow Hand 24 ~5 kg — — Public data
Allegro Hand 16 — — — Public data
LEAP Hand 16 — — — Public data

Baselines are compiled from public sources and simulation for reference only — not official vendor measurements. Are you the vendor? Claim your profile to submit verified physical metrics with test video.

Products

Start free in simulation. Scale to hardware and licensing.

Everything that can be delivered automatically ships instantly. Hardware and custom work go through a short qualified inquiry.

Community
Free
  • URDF & mesh models
  • Simplified SDK
  • Email delivery, no account needed
Most popular
Simulation Kit
¥1,999 ¥1,599 first year · launch −20%
  • Isaac Sim / MuJoCo environments
  • Grasping algorithms & datasets
  • One year of updates & API support
  • Launch bonus: dataset sample pack (HDF5 / RLDS)
Buy · lock in launch price
Developer Hardware
from ¥29,800
Model confirmed? Pay the deposit →
Enterprise
Custom
  • Industrial-grade licensing
  • Custom development & tuning
  • Private / on-prem deployment
Datasets as a service Grasping & manipulation datasets in HDF5 / RLDS, compatible with Hugging Face & LeRobot.
Remote Test Drive

Drive a real hand from your browser before you buy.

¥199 (remote simulation demo) / ¥499 (remote control of the real hand, 30 min): you command our hand or its digital twin through a grasp from your browser and receive a selection & API-fit report (PDF). The fee is fully credited against any hardware or subscription order.

  • Skip the “30-minute chat” — see capability directly
  • Report: recommended model, flange / electrical interface, ROS 2 integration steps, quote
  • Time slots and payment details within one business day

Book a Test Drive

We send time options and a payment link.

Fully credited · no newsletter · or pay now by QR / transfer →
Investors

A running system, not a pitch.

The data room shows the business as it actually operates today, with live traction — not a static deck.

TechnologyHand, simulation, control and safety layer
ProductsDigital subscriptions, hardware, licensing
TractionSDK downloads, orders, enterprise leads, revenue
RoadmapDeveloper kit → industrial hand → platform
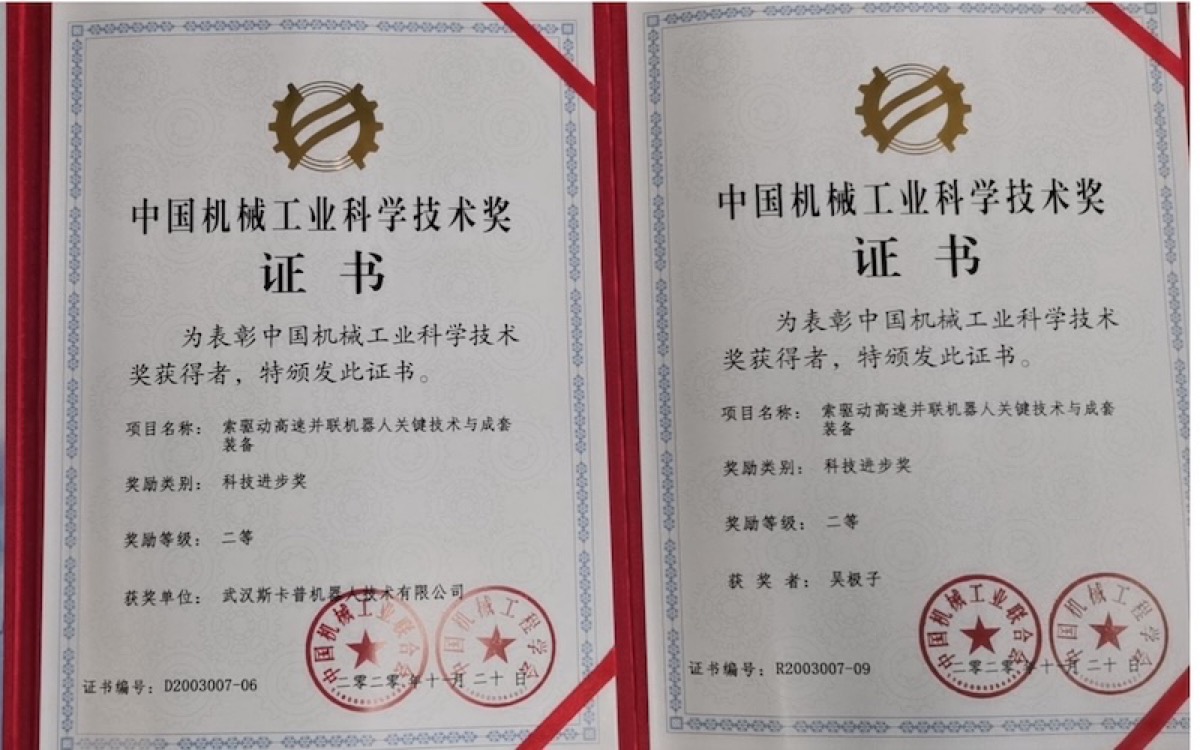
China Machinery Industry Science and Technology Award certificate
Team honours
China Machinery Industry Science & Technology Award · 2nd Prize, Scientific Progress (2020) Project "Cable-driven high-speed parallel robot: key technologies and complete equipment" · awarded to the team's predecessor company, Wuhan Scramp Robotics Technology Co., Ltd.

Request data room access

Enter a work email — access is granted per request and views are tracked.

We reply from the address below. No newsletter, no sharing.